浙江农业学报 ›› 2026, Vol. 38 ›› Issue (7): 1453-1462.DOI: 10.3969/j.issn.1004-1524.20250522
蔬菜大棚植保机器人定点施药算法研究
孟超( ), 李军英*(), 鲁政, 张金浩, 谌敬业
青岛科技大学 机电工程学院 山东 青岛 266061
-
收稿日期:2025-08-06出版日期:2026-07-25发布日期:2026-08-20 -
作者简介:孟超,主要从事机电系统智能化研究。E-mail:m15069473511@163.com -
通讯作者:*李军英,E-mail: 3176378268@qq.com
Research on the fixed-point pesticide application algorithm for vegetable greenhouse plant protection robot
MENG Chao(), LI Junying*(), LU Zheng, ZHANG Jinhao, CHEN Jingye
College of Electromechanical Engineering ,Qingdao University of Science and Technology Qingdao 266061, China
-
Received:2025-08-06Published:2026-07-25Online:2026-08-20

摘要: 针对青菜种植中病虫害精准施药的需求,提出了基于机器视觉和Faster R-CNN模型的定点施药算法,该算法包括病株检测算法和机械臂定点施药算法。利用机器视觉和Faster R-CNN模型实现病株检测,利用单目成像原理输出病株位置,利用定点施药算法控制并联机械臂定点施药。为验证算法的可行性,开展了仿真模拟和样机实验。结果表明,病株检测算法单次最大运算时间约为43.216 μs,满足系统1 ms通信周期的实时性要求;在100~200 mm·s-1行进速度下,并联机械臂定点施药算法的漏处理率和误处理率均低于5%,验证了算法的准确性与稳定性。本研究可为植保机器人精准施药提供技术参考。
中图分类号:
引用本文
孟超, 李军英, 鲁政, 张金浩, 谌敬业. 蔬菜大棚植保机器人定点施药算法研究[J]. 浙江农业学报, 2026, 38(7): 1453-1462.
MENG Chao, LI Junying, LU Zheng, ZHANG Jinhao, CHEN Jingye. Research on the fixed-point pesticide application algorithm for vegetable greenhouse plant protection robot[J]. Acta Agriculturae Zhejiangensis, 2026, 38(7): 1453-1462.
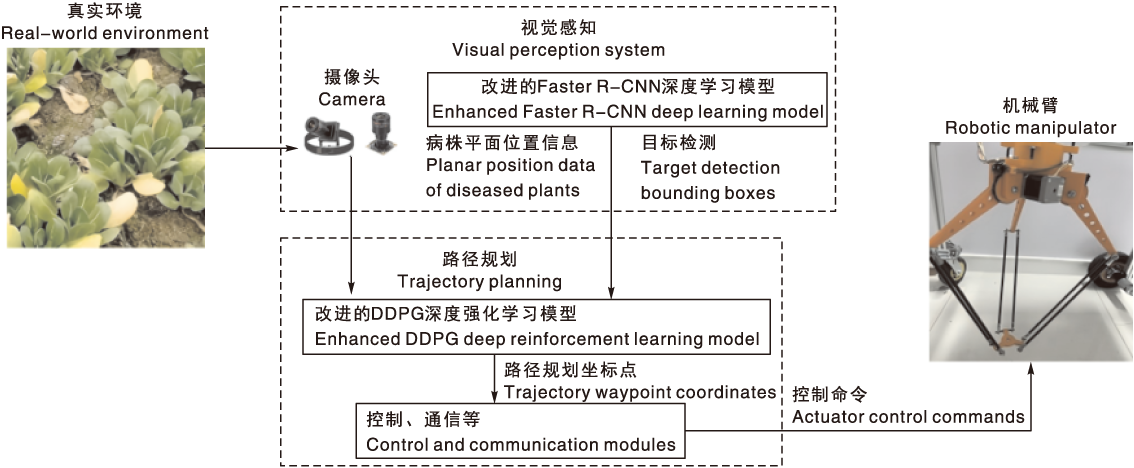
图1 深度强化学习实现方式
Fig.1 Implementation of deep reinforcement learning
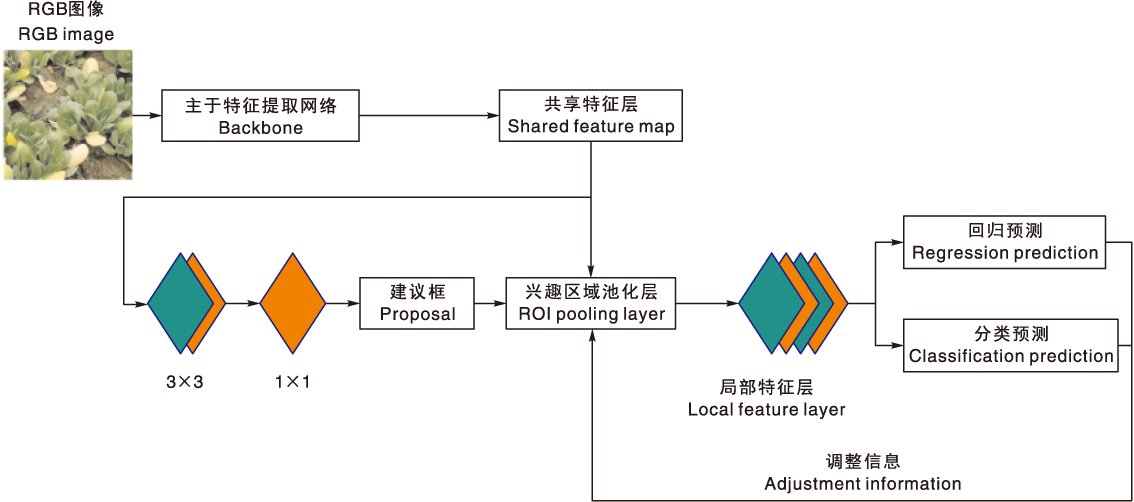
图2 Faster R-CNN模型结构
Fig.2 Faster R-CNN model structure
| 主干网络 Backbone network | 准确率/% Precision/% | 召回率/% Recall/% | F1值/% F1score/% | 检测时间/ms Inference time/ms |
|---|---|---|---|---|
| ResNet50 | 87.62 | 89.90 | 88.75 | 175.24 |
| ResNet10 | 88.33 | 90.85 | 89.57 | 174.89 |
| VGG-16 | 93.89 | 95.42 | 94.65 | 171.11 |
| VGG-19 | 89.25 | 89.34 | 89.29 | 173.67 |
表1 测试参数
Table 1 Test parameters
| 主干网络 Backbone network | 准确率/% Precision/% | 召回率/% Recall/% | F1值/% F1score/% | 检测时间/ms Inference time/ms |
|---|---|---|---|---|
| ResNet50 | 87.62 | 89.90 | 88.75 | 175.24 |
| ResNet10 | 88.33 | 90.85 | 89.57 | 174.89 |
| VGG-16 | 93.89 | 95.42 | 94.65 | 171.11 |
| VGG-19 | 89.25 | 89.34 | 89.29 | 173.67 |
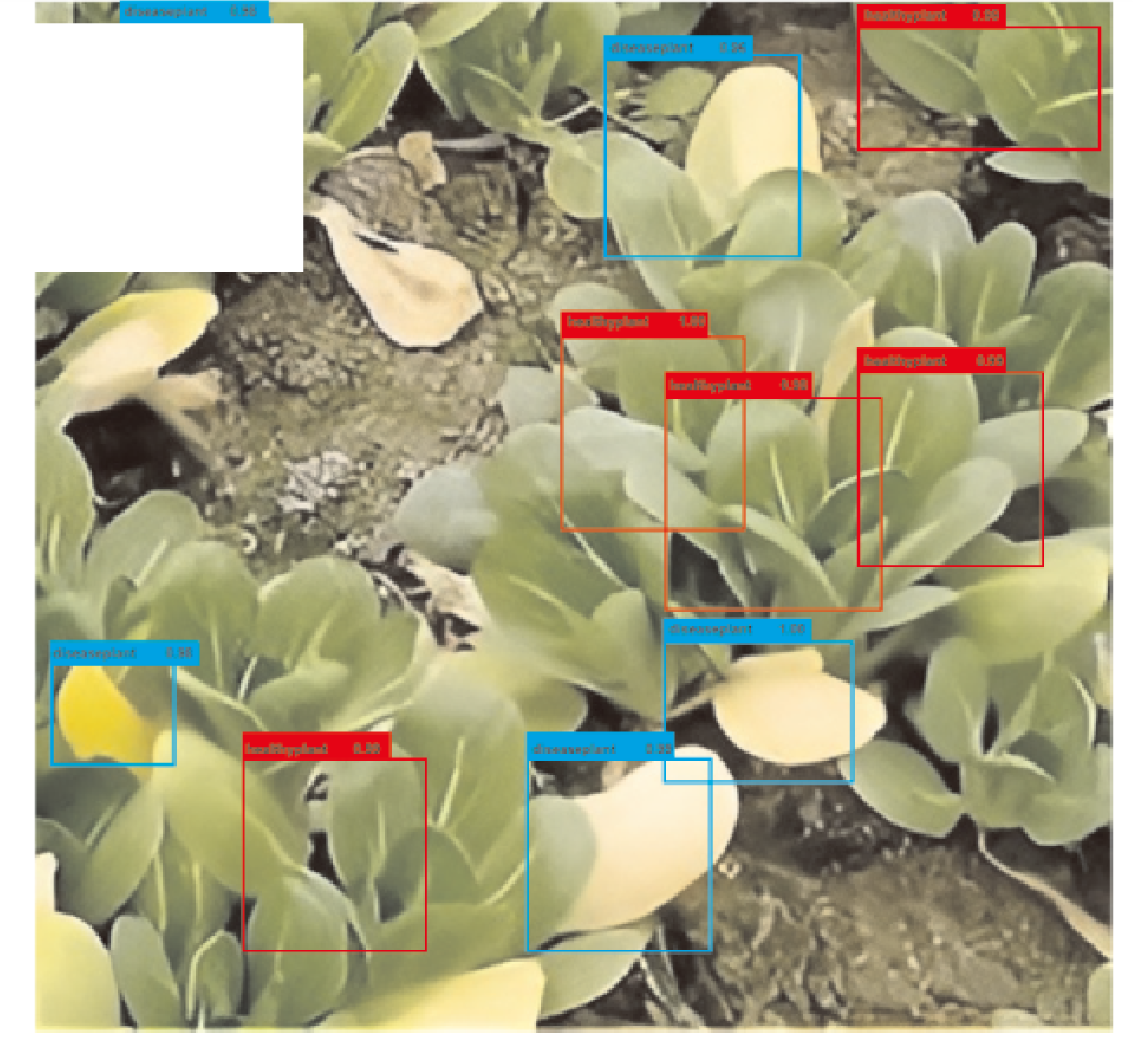
图3 VGG-16模型对健康与患病植株的检测结果示例
Fig.3 Detection examples of healthy and diseased plants by the VGG-16 model
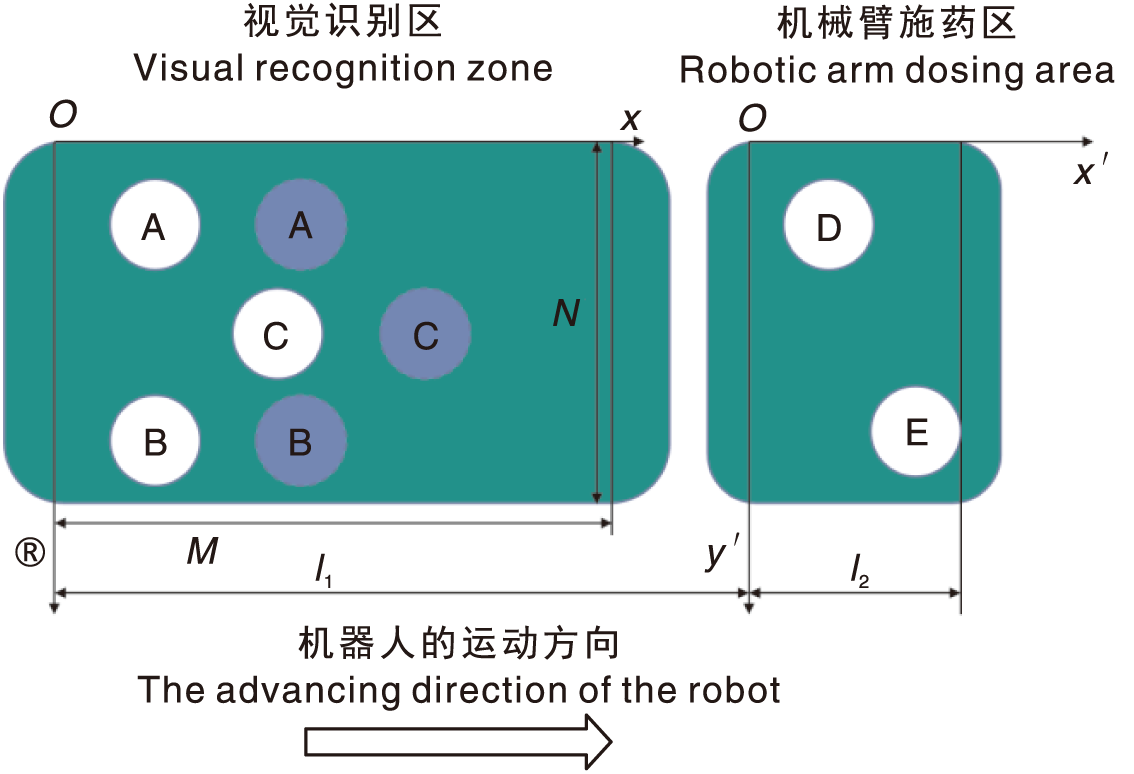
图4 视觉识别区与动态定点施药区示意图
Fig.4 Schematic diagram of visual identification zone and dynamic fixed-point spraying zone
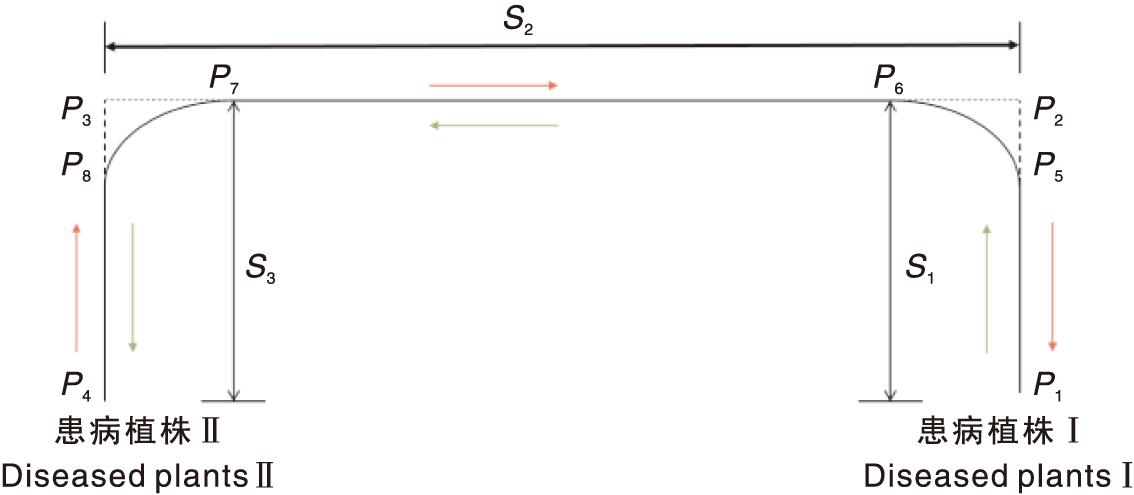
图5 门字形圆弧过渡施药机械臂路径
Fig.5 Door-shaped arc-transition spraying path of the robotic arm
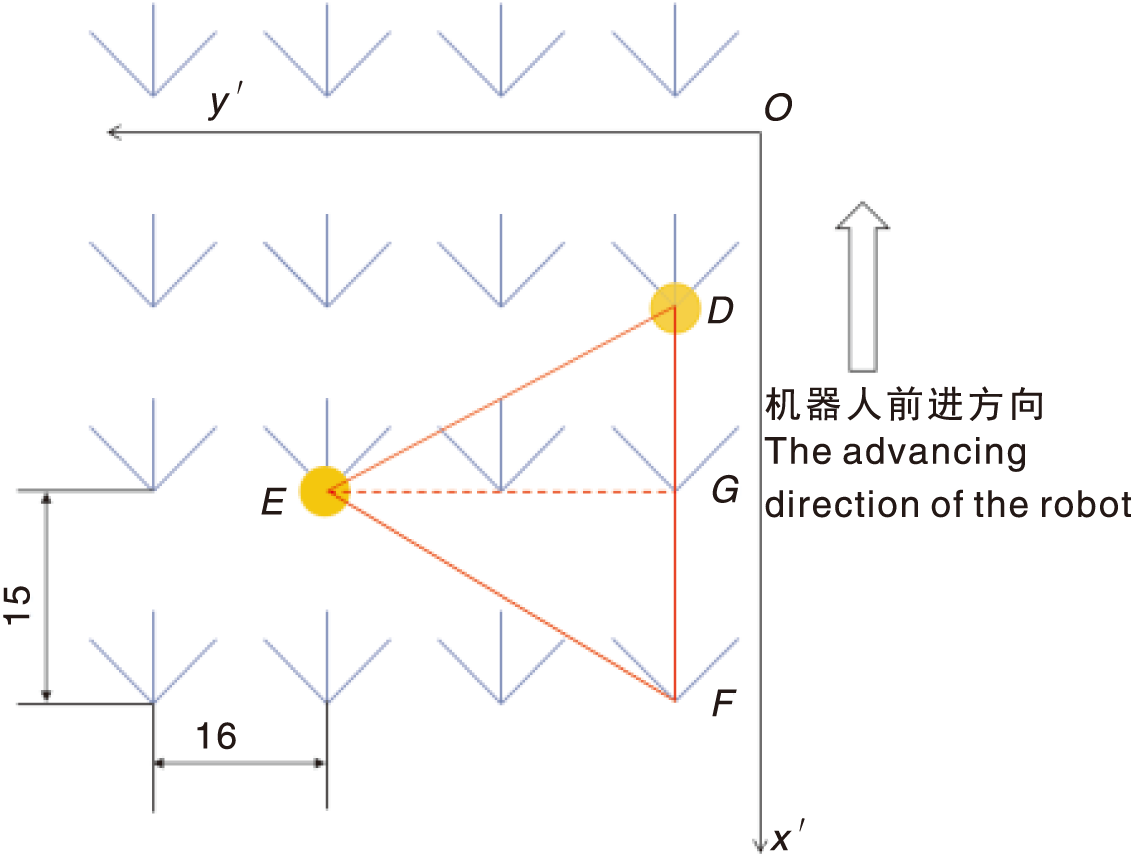
图6 动态定点施药示意图
Fig.6 Schematic diagram of dynamic targeted spraying
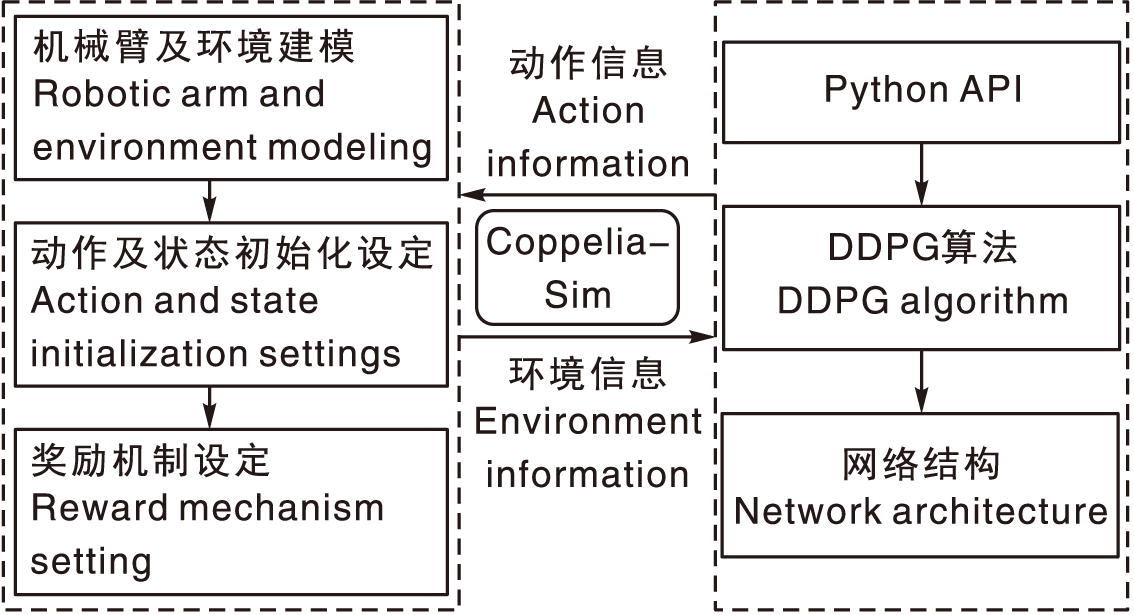
图7 仿真环境训练框架
Fig.7 Simulation environment training framework
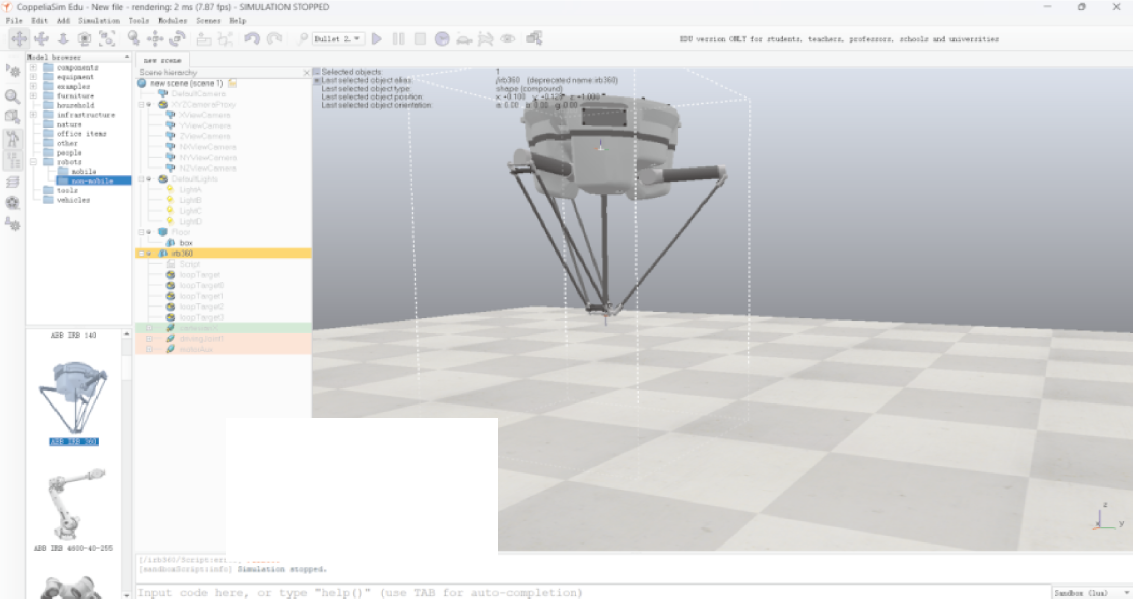
图8 CoppeliaSim仿真平台并联施药机械臂建模界面
Fig.8 Modeling interface of parallel spraying robotic arm in CoppeliaSim
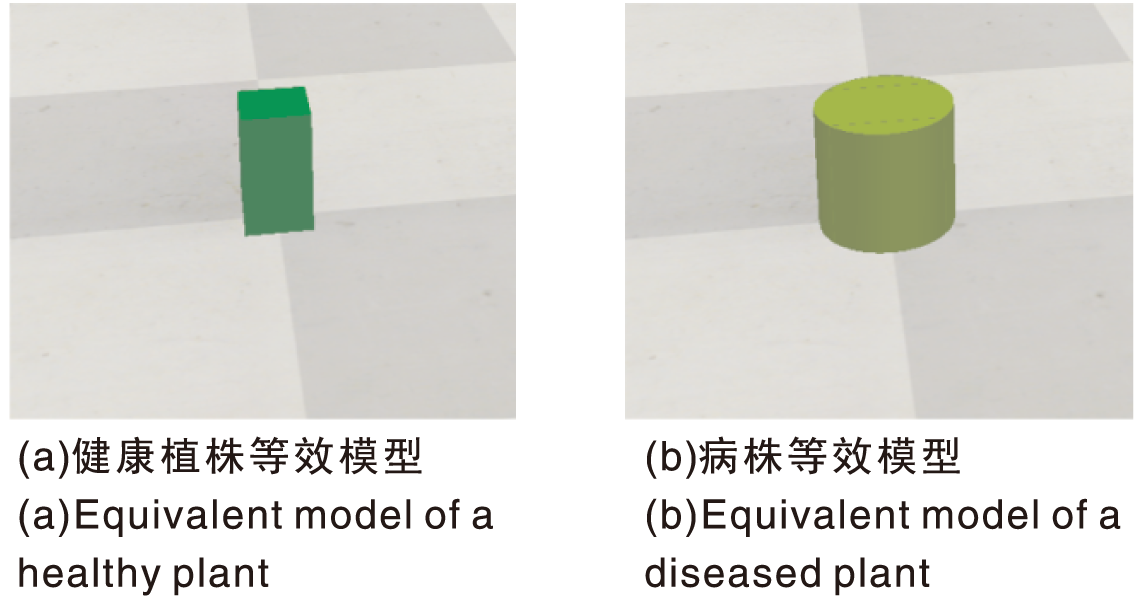
图9 青菜等效模型
Fig.9 Equivalent cubic model of bok choy
| 参数 Parameter | 值 Value |
|---|---|
| 行动者网络学习率Actor network learning rate | 0.000 1 |
| 评论家网络学习率Critic network learning rate | 0.001 |
| 训练轮数Number of training episodes | 2 000 |
| 回放缓冲区空间Replay buffer capacity | 80 000 |
| 单次更新采样Sampling batch size | 200 |
| 单次更新子集长度Subsequence length for each update | 10 |
| 损失系数Discount factor | 0.99 |
| 衰减系数Soft update coefficient | 1×10⁻⁴ |
表2 DDPG训练超参数设置
Table 2 Hyperparameter settings for DDPG training
| 参数 Parameter | 值 Value |
|---|---|
| 行动者网络学习率Actor network learning rate | 0.000 1 |
| 评论家网络学习率Critic network learning rate | 0.001 |
| 训练轮数Number of training episodes | 2 000 |
| 回放缓冲区空间Replay buffer capacity | 80 000 |
| 单次更新采样Sampling batch size | 200 |
| 单次更新子集长度Subsequence length for each update | 10 |
| 损失系数Discount factor | 0.99 |
| 衰减系数Soft update coefficient | 1×10⁻⁴ |
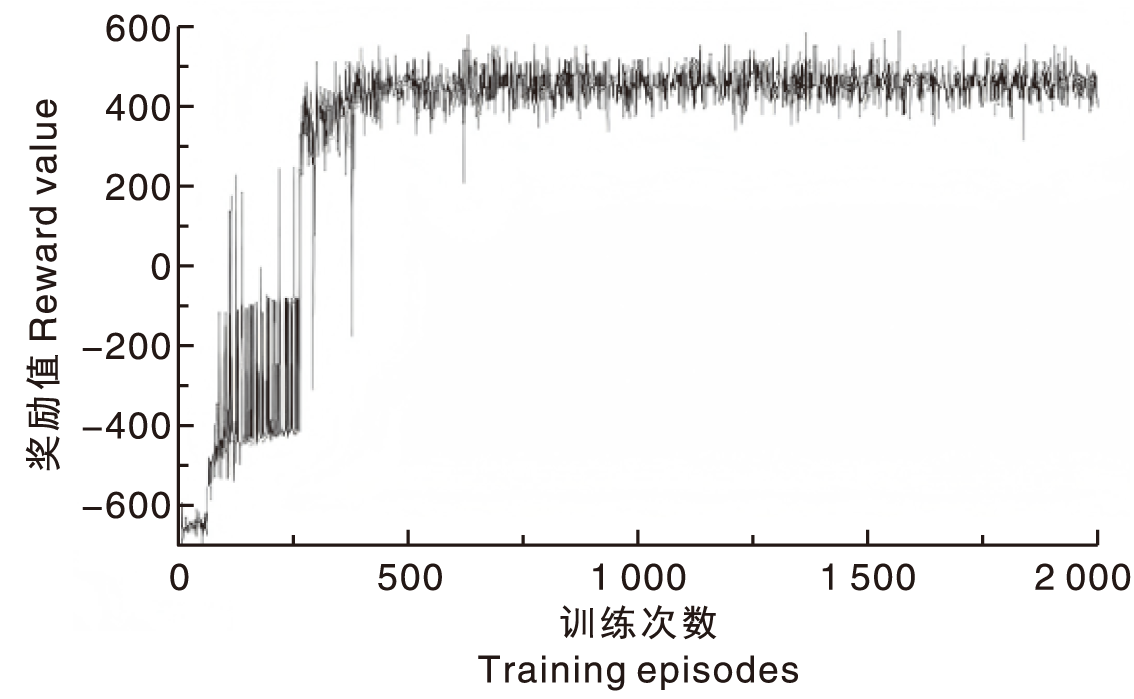
图10 DDPG模型学习曲线
Fig.10 Learning curve of the DDPG model
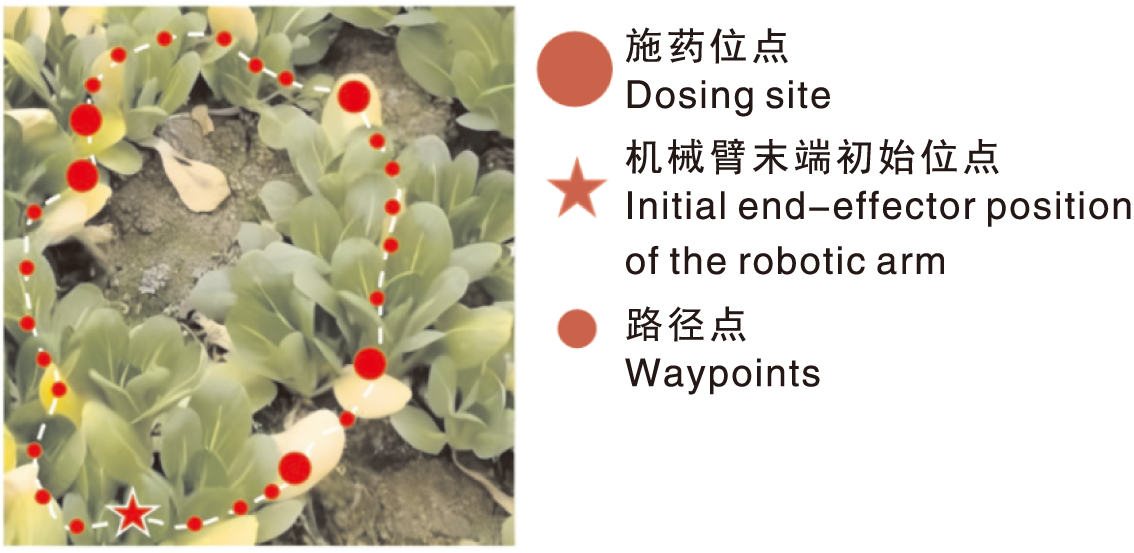
图11 DDPG路径坐标图像平面投影示意图
Fig.11 Schematic diagram of DDPG path coordinate projection onto the image plane
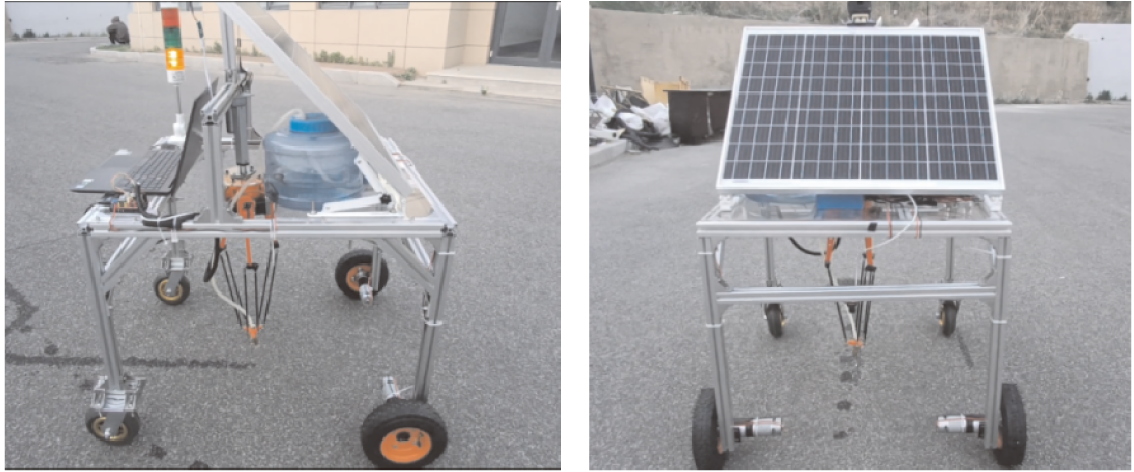
图12 实验样机
Fig.12 Experimental prototype
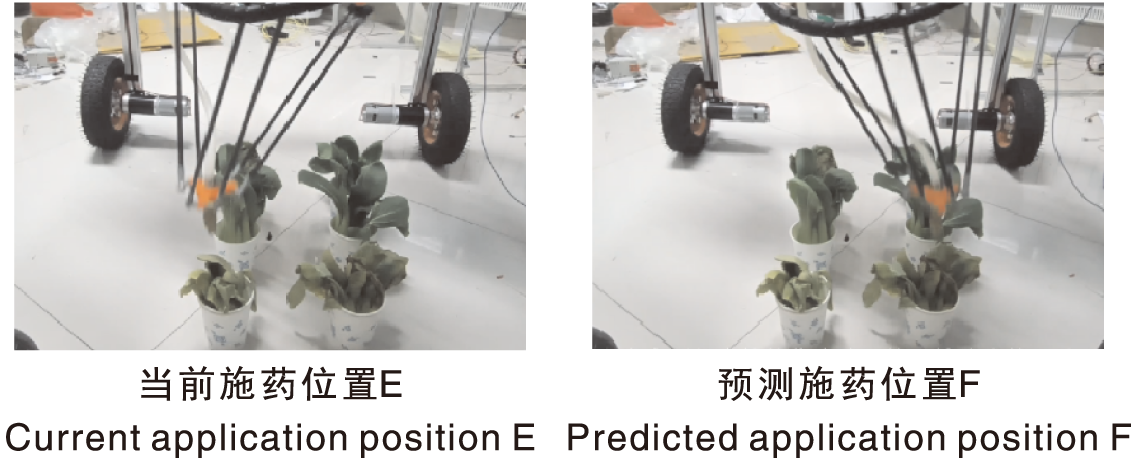
图13 运算时间测试结果
Fig.13 Computing time test of the disease plant detection algorithm
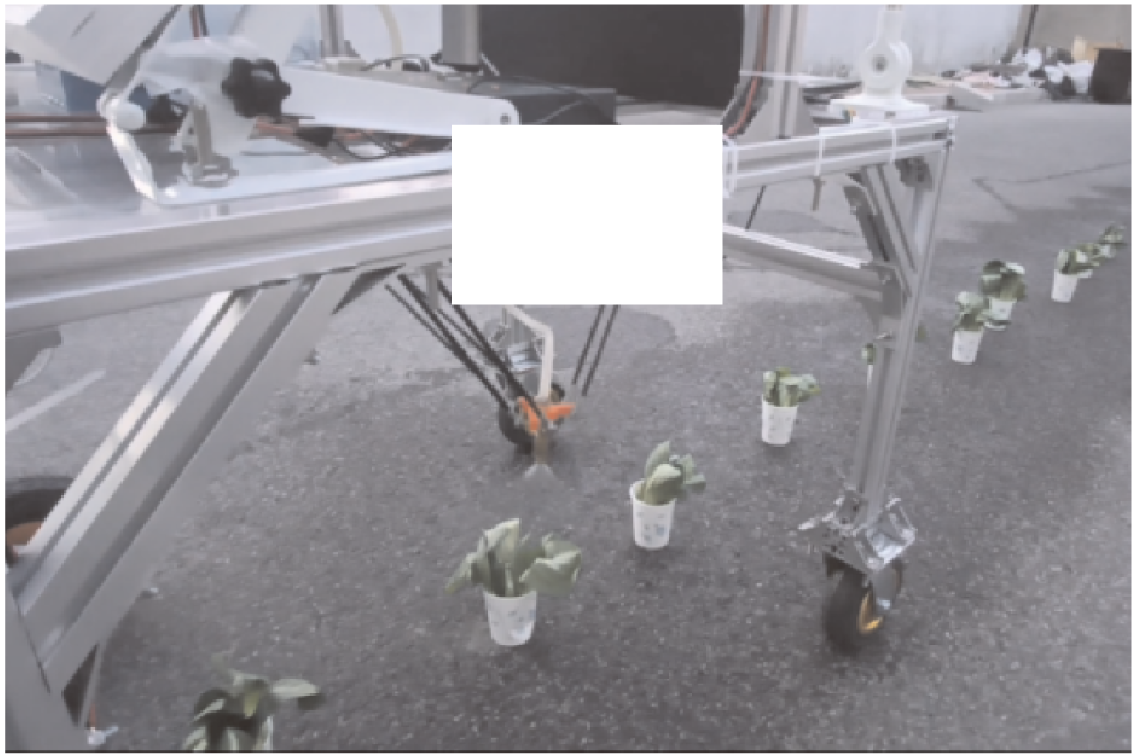
图14 动态定点施药实验
Fig.14 Dynamic spot application experiment
| 机器人行进 速度/(mm·s-1) Robot traveling speed/(mm·s-1) | 患病植株 总个数 Total number of diseased plants | 漏处理个数 Number of missed plants | 误处理个数 Number of falsely treated plants |
|---|---|---|---|
| 100 | 24 | 0 | 0 |
| 150 | 27 | 1 | 1 |
| 200 | 21 | 1 | 1 |
表3 不同行进速度下样机实验结果
Table 3 Experimental results of the prototype under different traveling speeds
| 机器人行进 速度/(mm·s-1) Robot traveling speed/(mm·s-1) | 患病植株 总个数 Total number of diseased plants | 漏处理个数 Number of missed plants | 误处理个数 Number of falsely treated plants |
|---|---|---|---|
| 100 | 24 | 0 | 0 |
| 150 | 27 | 1 | 1 |
| 200 | 21 | 1 | 1 |
| [1] | 唐烁. 农业面源污染多维度影响及其治理机制优化研究[D]. 哈尔滨: 东北林业大学, 2023. |
| Tang S. Research on the multidimensional impact of agricultural non-point source pollution and optimization of its governance mechanism[D]. Harbin: Northeast Forestry University, 2023. | |
| [2] | 张军勇, 袁立贺. 农药利用率低的原因及改进措施[J]. 农业工程技术, 2018, 38(8): 39. |
| Zhang J Y, Yuan L H. Causes and improvement measures of low utilization rate of pesticides[J]. Agricultural Engineering Technology, 2018, 38(8): 39. | |
| [3] | Yang X, Shu L, Chen J N, et al. A survey on smart agriculture: development modes, technologies, and security and privacy challenges[J]. IEEE/CAA Journal of Automatica Sinica, 2021, 8(2): 273-302. |
| [4] | 邓科. 农业机器人技术在农业工程中的应用及发展趋势[J]. 农机使用与维修, 2023(9): 94-97. |
| Deng K. Research on the application of agricultural robotics in agricultural engineering[J]. Agricultural Machinery Using & Maintenance, 2023(9): 94-97. | |
| [5] | 周维, 牛永真, 王亚炜, 等. 基于改进的YOLOv4-GhostNet水稻病虫害识别方法[J]. 江苏农业学报, 2022, 38(3): 685-695. |
| Zhou W, Niu Y Z, Wang Y W, et al. Rice pests and diseases identification method based on improved YOLOv4-GhostNet[J]. Jiangsu Journal of Agricultural Sciences, 2022, 38(3): 685-695. | |
| [6] | 刘鹏, 张天翼, 冉鑫, 等. 基于PBM-YOLOv8的水稻病虫害检测[J]. 农业工程学报, 2024, 40(20): 147-156. |
| Liu P, Zhang T Y, Ran X, et al. Detecting rice disease using PBM-YOLOv8[J]. Transactions of the Chinese Society of Agricultural Engineering, 2024, 40(20): 147-156. | |
| [7] | 刘诗怡, 胡滨, 赵春. 基于改进YOLOv7的黄瓜叶片病虫害检测与识别[J]. 农业工程学报, 2023, 39(15): 163-171. |
| Liu S Y, Hu B, Zhao C. Detection and identification of cucumber leaf diseases based improved YOLOv7[J]. Transactions of the Chinese Society of Agricultural Engineering, 2023, 39(15): 163-171. | |
| [8] | 宋中山, 汪进, 郑禄, 等. 基于二值化的Faster R-CNN柑橘病虫害识别研究[J]. 中国农机化学报, 2022, 43(6): 150-158. |
| Song Z S, Wang J, Zheng L, et al. Research on citrus pest identification based on Binary Faster R-CNN[J]. Journal of Chinese Agricultural Mechanization, 2022, 43(6): 150-158. | |
| [9] | 彭红星, 徐慧明, 刘华鼐. 融合双分支特征和注意力机制的葡萄病虫害识别模型[J]. 农业工程学报, 2022, 38(10): 156-165. |
| Peng H X, Xu H M, Liu H N. Model for identifying grape pests and diseases based on two-branch feature fusion and attention mechanism[J]. Transactions of the Chinese Society of Agricultural Engineering, 2022, 38(10): 156-165. | |
| [10] | 高杨, 肖迪. 基于多层特征融合的小目标检测算法[J]. 计算机工程与设计, 2020, 41(7): 1905-1909. |
| Gao Y, Xiao D. Small object detection algorithm based on multi-feature fusion[J]. Computer Engineering and Design, 2020, 41(7): 1905-1909. | |
| [11] | 乔赫廷, 张然, 王黠. 基于共面靶标的线结构光机器人视觉标定方法[J]. 机械工程师, 2024(3): 21-25. |
| Qiao H T, Zhang R, Wang X. Visual calibration method of linear structured light robot based on coplanar target[J]. Mechanical Engineer, 2024(3): 21-25. | |
| [12] | 王艳. 高效除草机器人控制系统设计[D]. 南京: 南京林业大学, 2013. |
| Wang Y. Researches on the control system for a high-efficient weeding robot[D]. Nanjing: Nanjing Forestry University, 2013. | |
| [13] | 于金刚, 林浒, 张晓辉, 等. 一种新型的Jerk连续加减速控制方法研究[J]. 组合机床与自动化加工技术, 2009(8): 61-64. |
| Yu J G, Lin H, Zhang X H, et al. Research on a novel acceleration and deceleration control method of continuous Jerk[J]. Modular Machine Tool & Automatic Manufacturing Technique, 2009(8): 61-64. | |
| [14] | 王云飞, 郎需林, 张承瑞, 等. 高速并联机械手最优加减速控制算法研究[J]. 机械设计与制造, 2014(11): 85-88. |
| Wang Y F, Lang X L, Zhang C R, et al. The optimal acceleration-deceleration control research of high-speed parallel manipulator[J]. Machinery Design & Manufacture, 2014(11): 85-88. | |
| [15] | 童明浩. 四自由度Delta并联机械手结构与控制系统研究[D]. 武汉: 湖北工业大学, 2016. |
| Tong M H. Research on structure and control system of 4-DOF Delta parallel manipulator[D]. Wuhan: Hubei University of Technology, 2016. |
| [1] | 欧阳宇, 刘朔, 李萌民, 张鹏. 轻量化改进的苹果园果实识别模型CS_YOLOv7[J]. 浙江农业学报, 2026, 38(2): 383-396. |
| [2] | 吕胤春, 段恩泽, 朱一星, 郑霞, 柏宗春. 基于YOLOv8-Swin Transformer模型的翻覆肉鸭实时检测[J]. 浙江农业学报, 2025, 37(7): 1556-1566. |
| [3] | 李萌民, 刘朔, 欧阳宇, 张鹏. 基于YOLOv8n的高效轻量化柑橘叶片病害检测模型[J]. 浙江农业学报, 2025, 37(10): 2198-2208. |
| [4] | 郭秀明, 王大伟, 刘升平, 诸叶平, 刘晓辉, 林克剑, 王佳宇, 李非. 基于深度学习的近地面草原鼠洞识别计数关键问题研究与应用[J]. 浙江农业学报, 2024, 36(9): 2146-2154. |
| [5] | 宁文楷, 李静, 沈晓东, 吴鑫, 李臻锋. 南瓜干燥过程中β-胡萝卜素的多源融合预测[J]. 浙江农业学报, 2023, 35(8): 1876-1887. |
| [6] | 闫宁, 张晗, 董宏图, 康凯, 罗斌. 基于透射光和反射光图像同位分割的小麦品种识别方法研究[J]. 浙江农业学报, 2022, 34(3): 590-598. |
| [7] | 包晓敏, 盛家文. 粘虫板害虫自动识别计数研究[J]. 浙江农业学报, 2019, 31(9): 1516-1522. |
| [8] | 伍渊远, 尚欣, 张呈彬, 谢新义. 自然光照下智能叶菜收获机作业参数的获取[J]. 浙江农业学报, 2017, 29(11): 1930-1937. |
| [9] | 田海韬, 赵军, 蒲富鹏. 马铃薯芽眼图像的分割与定位方法[J]. 浙江农业学报, 2016, 28(11): 1947-1953. |
| [10] | 任磊1,张俊2,*,陆胜民2. 脱囊衣橘片自动分拣机器视觉算法研究[J]. 浙江农业学报, 2015, 27(12): 2212-. |
| [11] | 刘建军;姚立健;彭樟林. 基于机器视觉的山核桃等级检测技术[J]. , 2010, 22(6): 854-858. |
| [12] | 梁琨;罗汉亚;沈明霞;*;何瑞银;张璐. 水稻播种质量检测技术的研究进展及展望[J]. , 2010, 22(2): 0-257. |
| [13] | 王勇;沈明霞;姬长英. 基于色差信息的田间成熟棉花识别[J]. , 2007, 19(5): 0-388. |
| 阅读次数 | ||||||
|
全文 |
|
|||||
|
摘要 |
|
|||||

